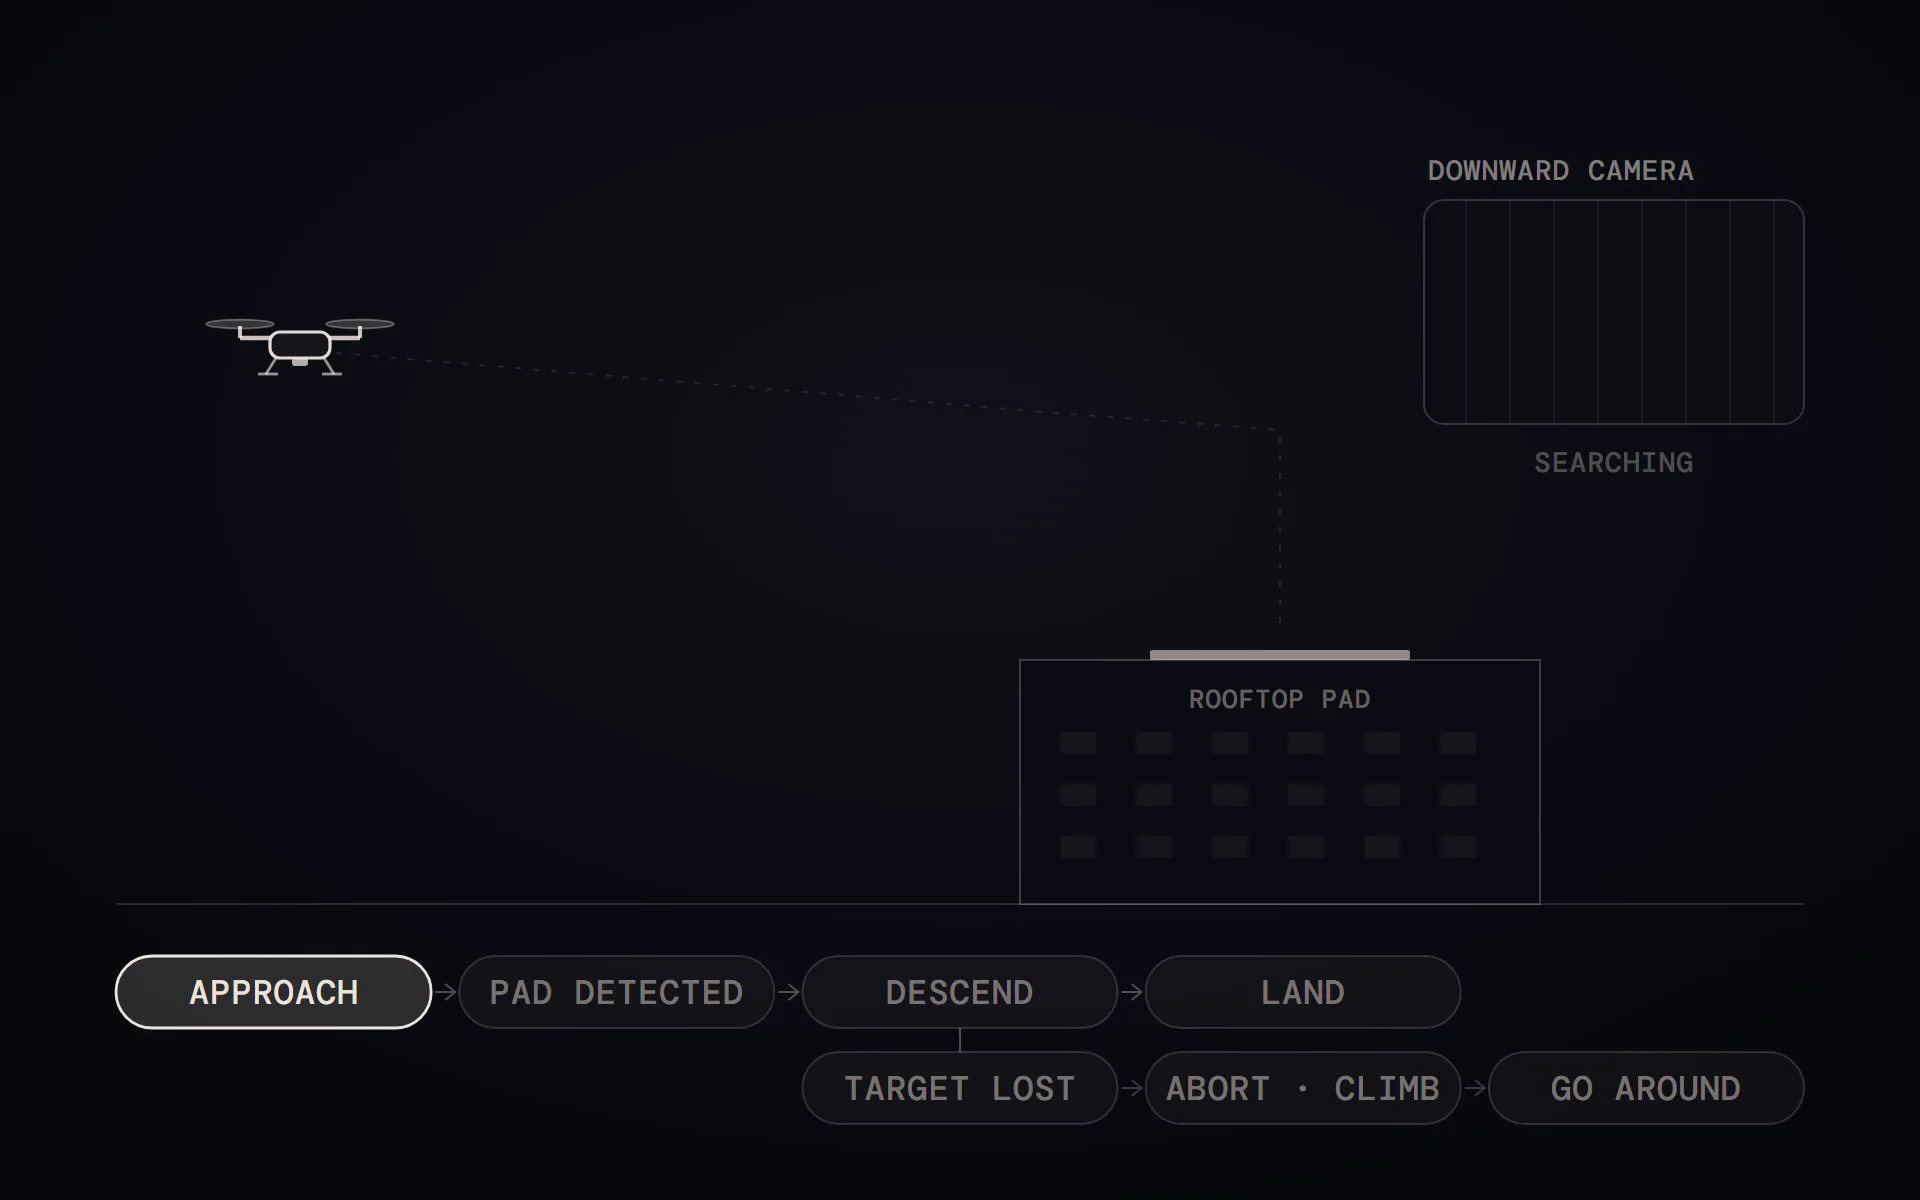
The job
A drone must find a rooftop pad and land on it. If it loses the pad, it must abort, climb and go around. It all runs in simulation.
The logic
The mission is a set of states with two paths: land, or abort and go around. This is the part I write.
- Approach
- Pad detected
- Descend
- Land
- Target lost
- Abort · climb
- Go around
Two parts
The work is split so you can see exactly what is mine.
Part 1 · agent-built
The platform
- Simulation tooling
- Replay viewer
- Run validator
- Automated tests
Public. AI agents build it, and I direct and review the work.
Part 2 · my own code
Landing logic
- Mission state machine
- Frame chain
- Estimator
- Abort logic
Not public yet. I write it myself, with no AI-written code. It goes public with its first simulated flight.
What works today
- A scripted mission in the simulator: takeoff to 5 m, hold, land (ArduPilot Copter 4.7.2).
- A log exporter for the simulator's messages (MAVLink).
- A replay viewer, built with three.js.
- A run validator, written in Rust.
- Automated tests (CI).
How it is tested
Random seeds are registered before the runs. Some tests are held out. Results will come with confidence intervals, and failures will be reported.
There are no landing-accuracy numbers yet. They go here after the first simulated flights with my landing code.
Next
Milestone 1: the first flight with my landing code, in the simulator.